What we do

Research

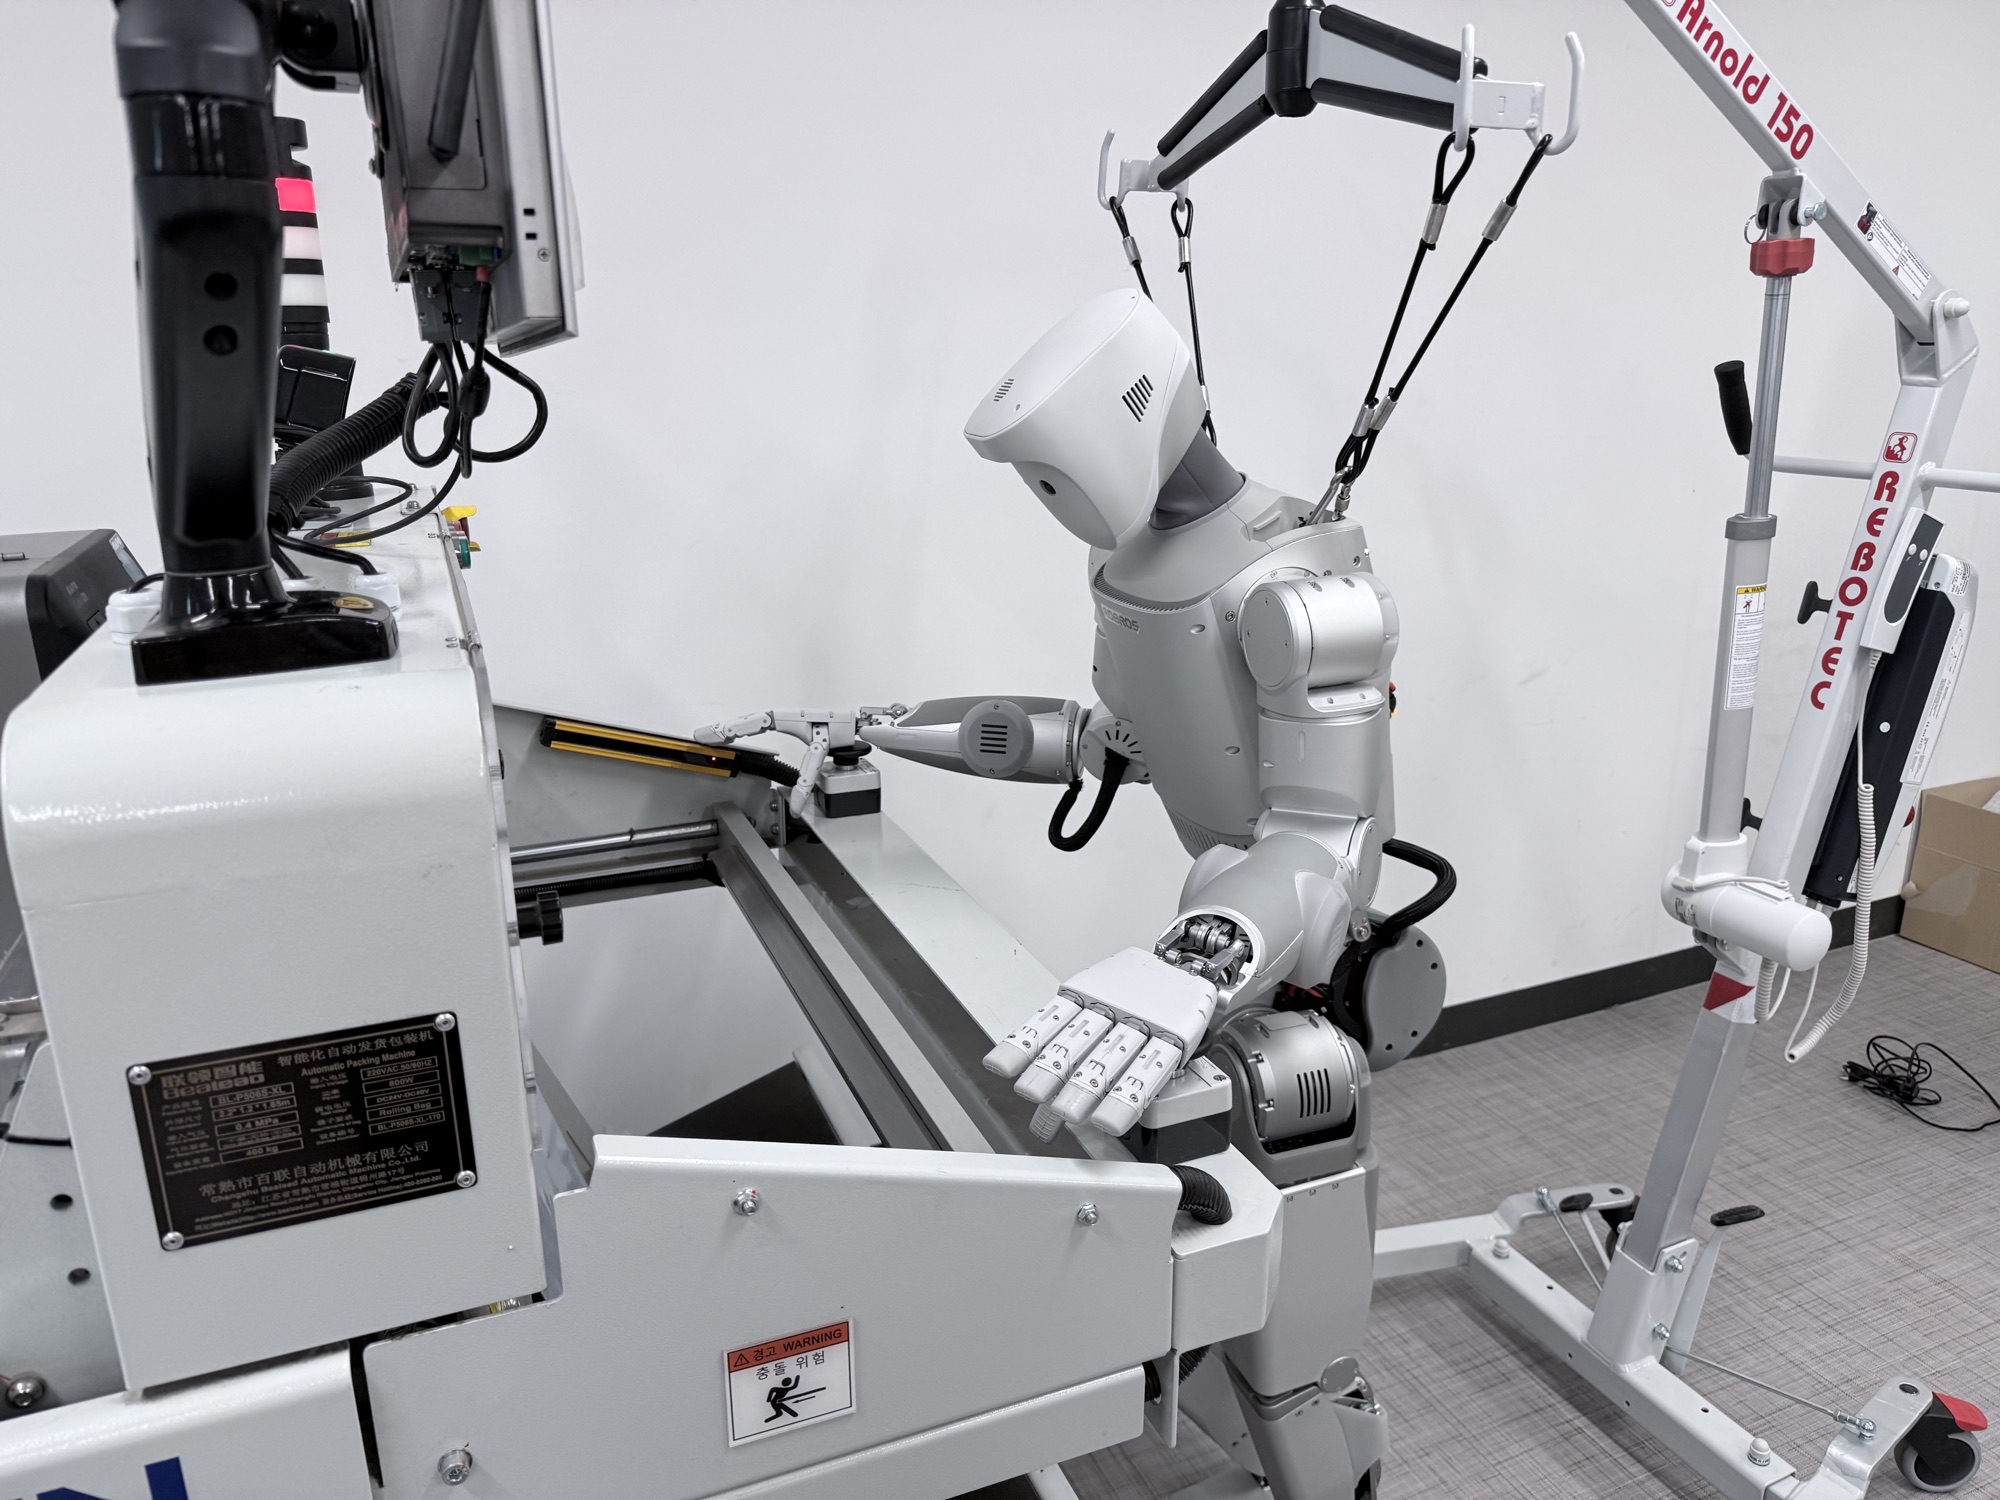
From arm manipulation to mobile manipulators and humanoids — robots that work autonomously in dynamic environments.

Research Topics

Motion Planning

01

Motion Planning

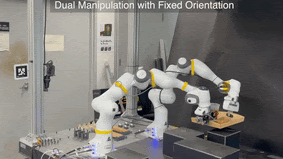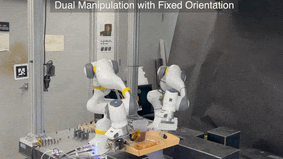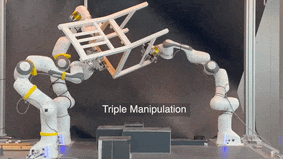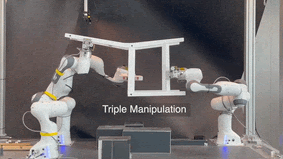
Planning feasible grasps and motions under kinematic, closed-chain, and task constraints — from single arms to whole-body systems.

  • Grasp Planning
  • Whole-body Motion Planning
  • Constrained Motion Planning

Related publications

  • Connectivity-Aware Representations for Constrained Motion Planning via Multi-Scale Contrastive Learning IEEE ICRA 2026arXiv
  • A Constrained Motion Planning Method Exploiting Learned Latent Space for High-Dimensional State and Constraint Spaces IEEE/ASME T-MECH 2024Paper
  • Motion Planning for Closed-Chain Constraints Based on Probabilistic Roadmap With Improved Connectivity IEEE/ASME T-MECH 2022Paper
  • Scalable Learned Geometric Feasibility for Cooperative Grasp and Motion Planning IEEE RA-L 2022Paper
Physical AI

02

Physical AI

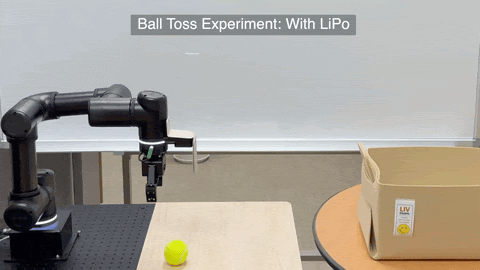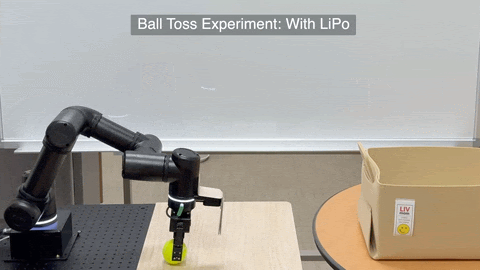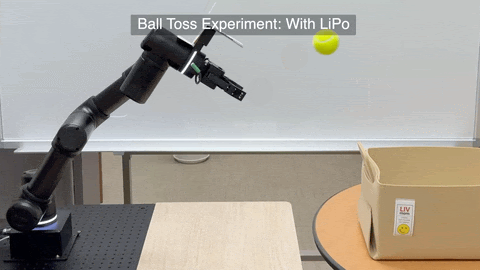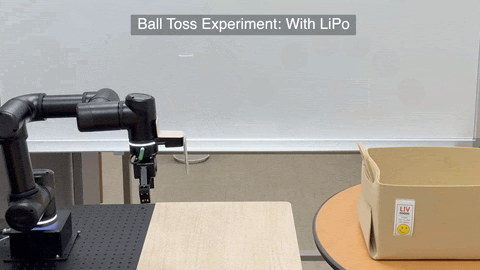
Learning manipulation skills from data — imitation learning, vision-language-action models, teleoperation for data collection, and post-optimization of learned policies.

  • Post-optimization Algorithm
  • Vision-Language-Action Models
  • Imitation Learning
  • Teleoperation
  • Dataset Augmentation

Related publications

  • SNU-Avatar Haptic Arm: A Hybrid QDD/DD Operator Interface for Teleoperation IEEE Access 2026Paper
  • LiPo: A Lightweight Post-optimization Framework for Smoothing Action Chunks Generated by Learned Policies IJCAS 2025Paper
  • Intuitive and Interactive Robotic Avatar System for Tele-Existence: TEAM SNU in the ANA Avatar XPRIZE Finals IJSR 2024Paper
Humanoids

03

Humanoids

Whole-body manipulation and bipedal walking for humanoid robots working in real environments.

  • Whole-body Manipulation
  • Bipedal Walking

Related publications

  • Dual-Channel EtherCAT Control System for 33-DOF Humanoid Robot TOCABI IEEE Access 2023Paper

Projects

Funded Projects