
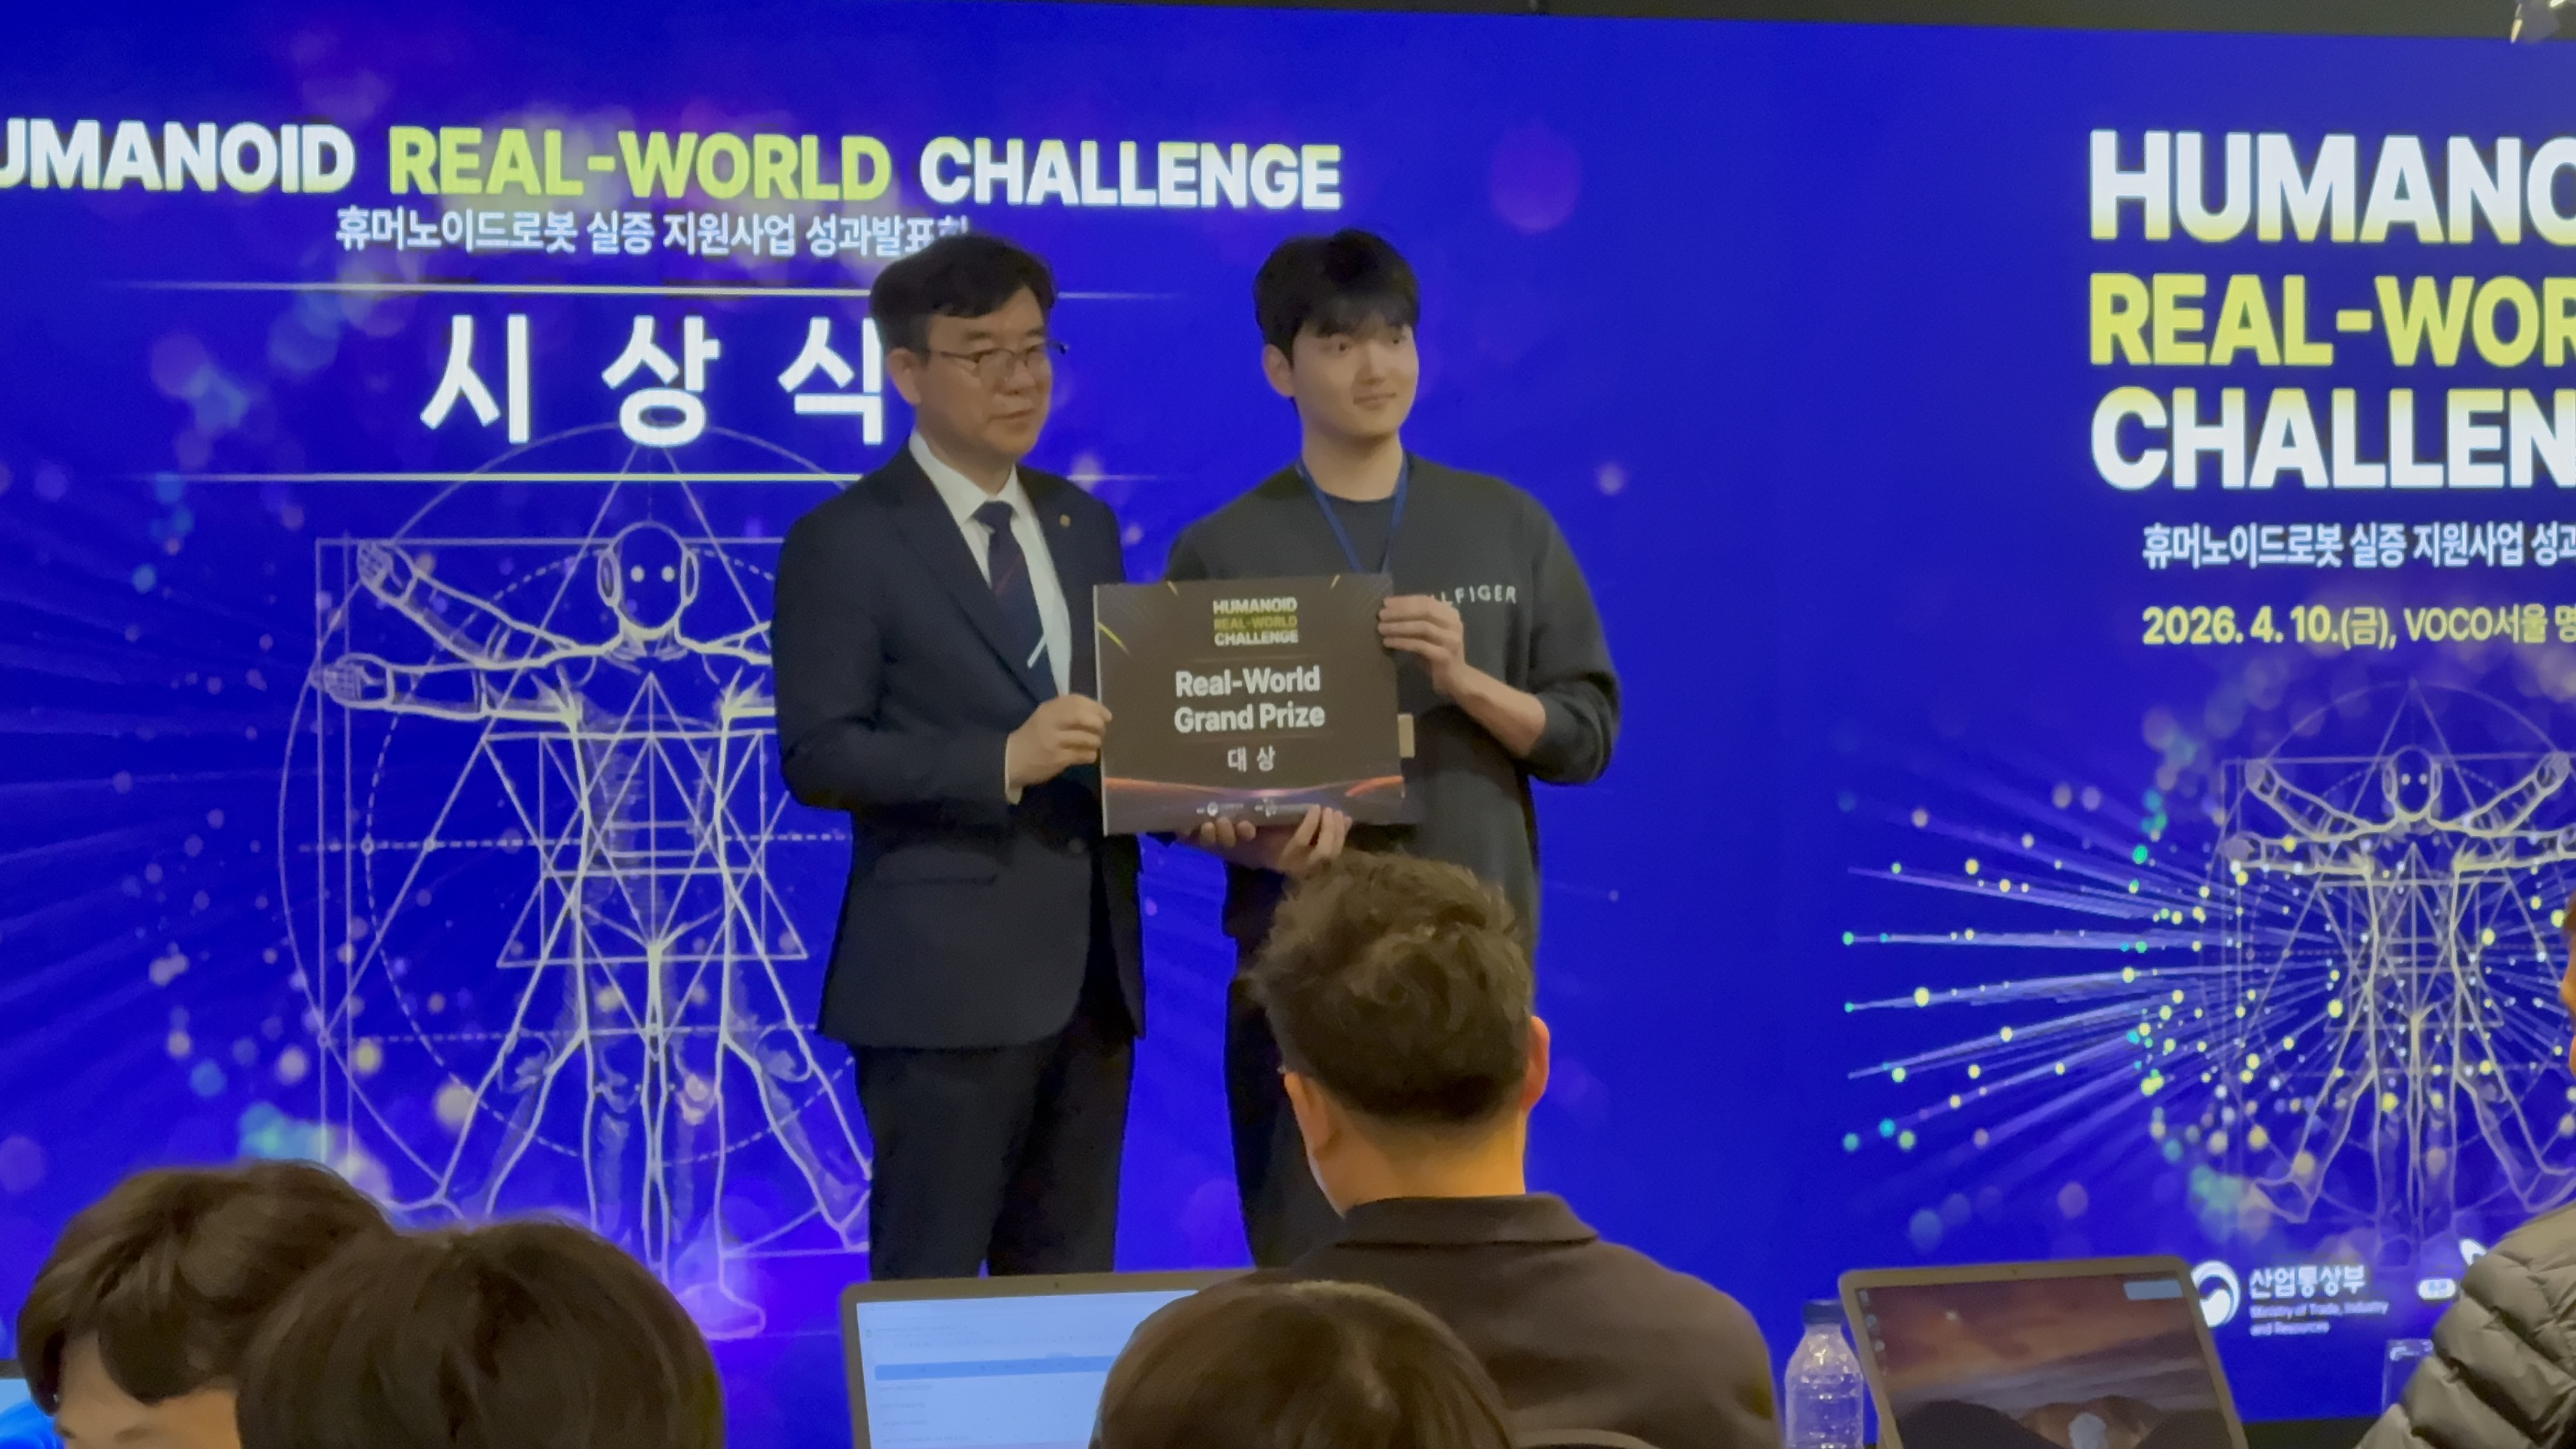
1st Place Humanoid Real-World Challenge
The first public demonstration of bipedal, Physical AI–based garment-packing automation
Recognized for a field demonstration in which the ROBROS humanoid IGRIS performed garment packing at a Lotte Global Logistics site — a representative case of a humanoid carrying out unstructured manipulation in a real industrial setting.
Team Dongwoo Son, Junho An, Chanwoo Seon, Jinwoo Lee
- ROBROS IGRIS C
- Lotte Global Logistics
- Garment-Packing Automation
- Manipulation