
01
Motion Planning
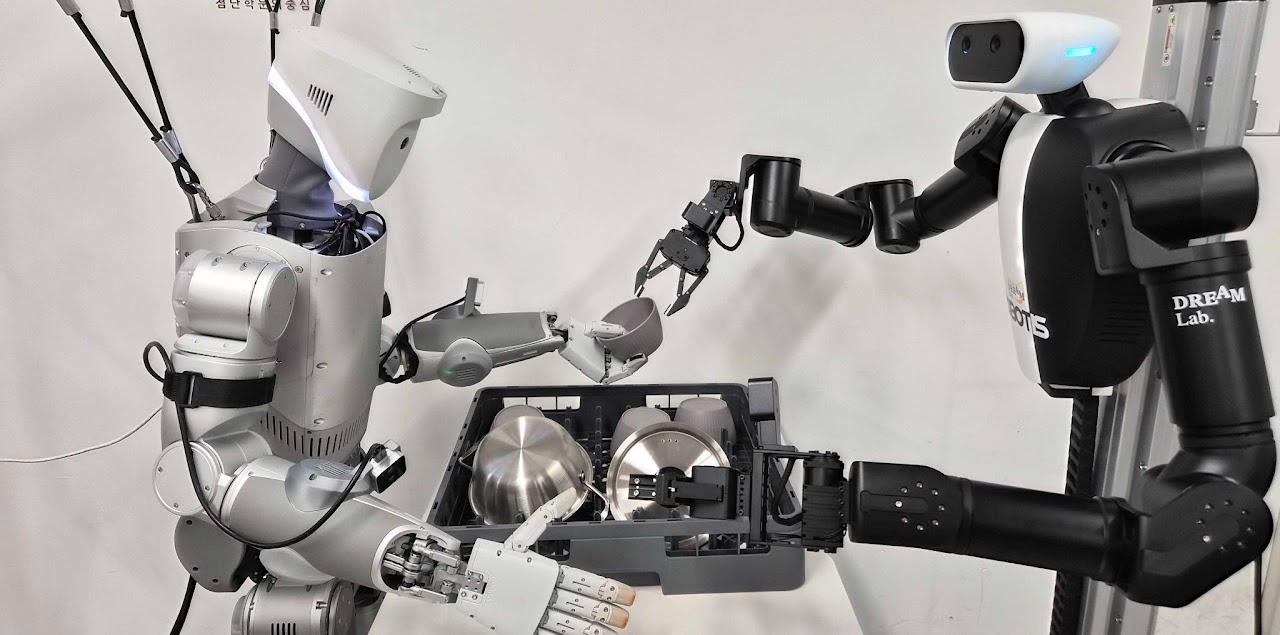
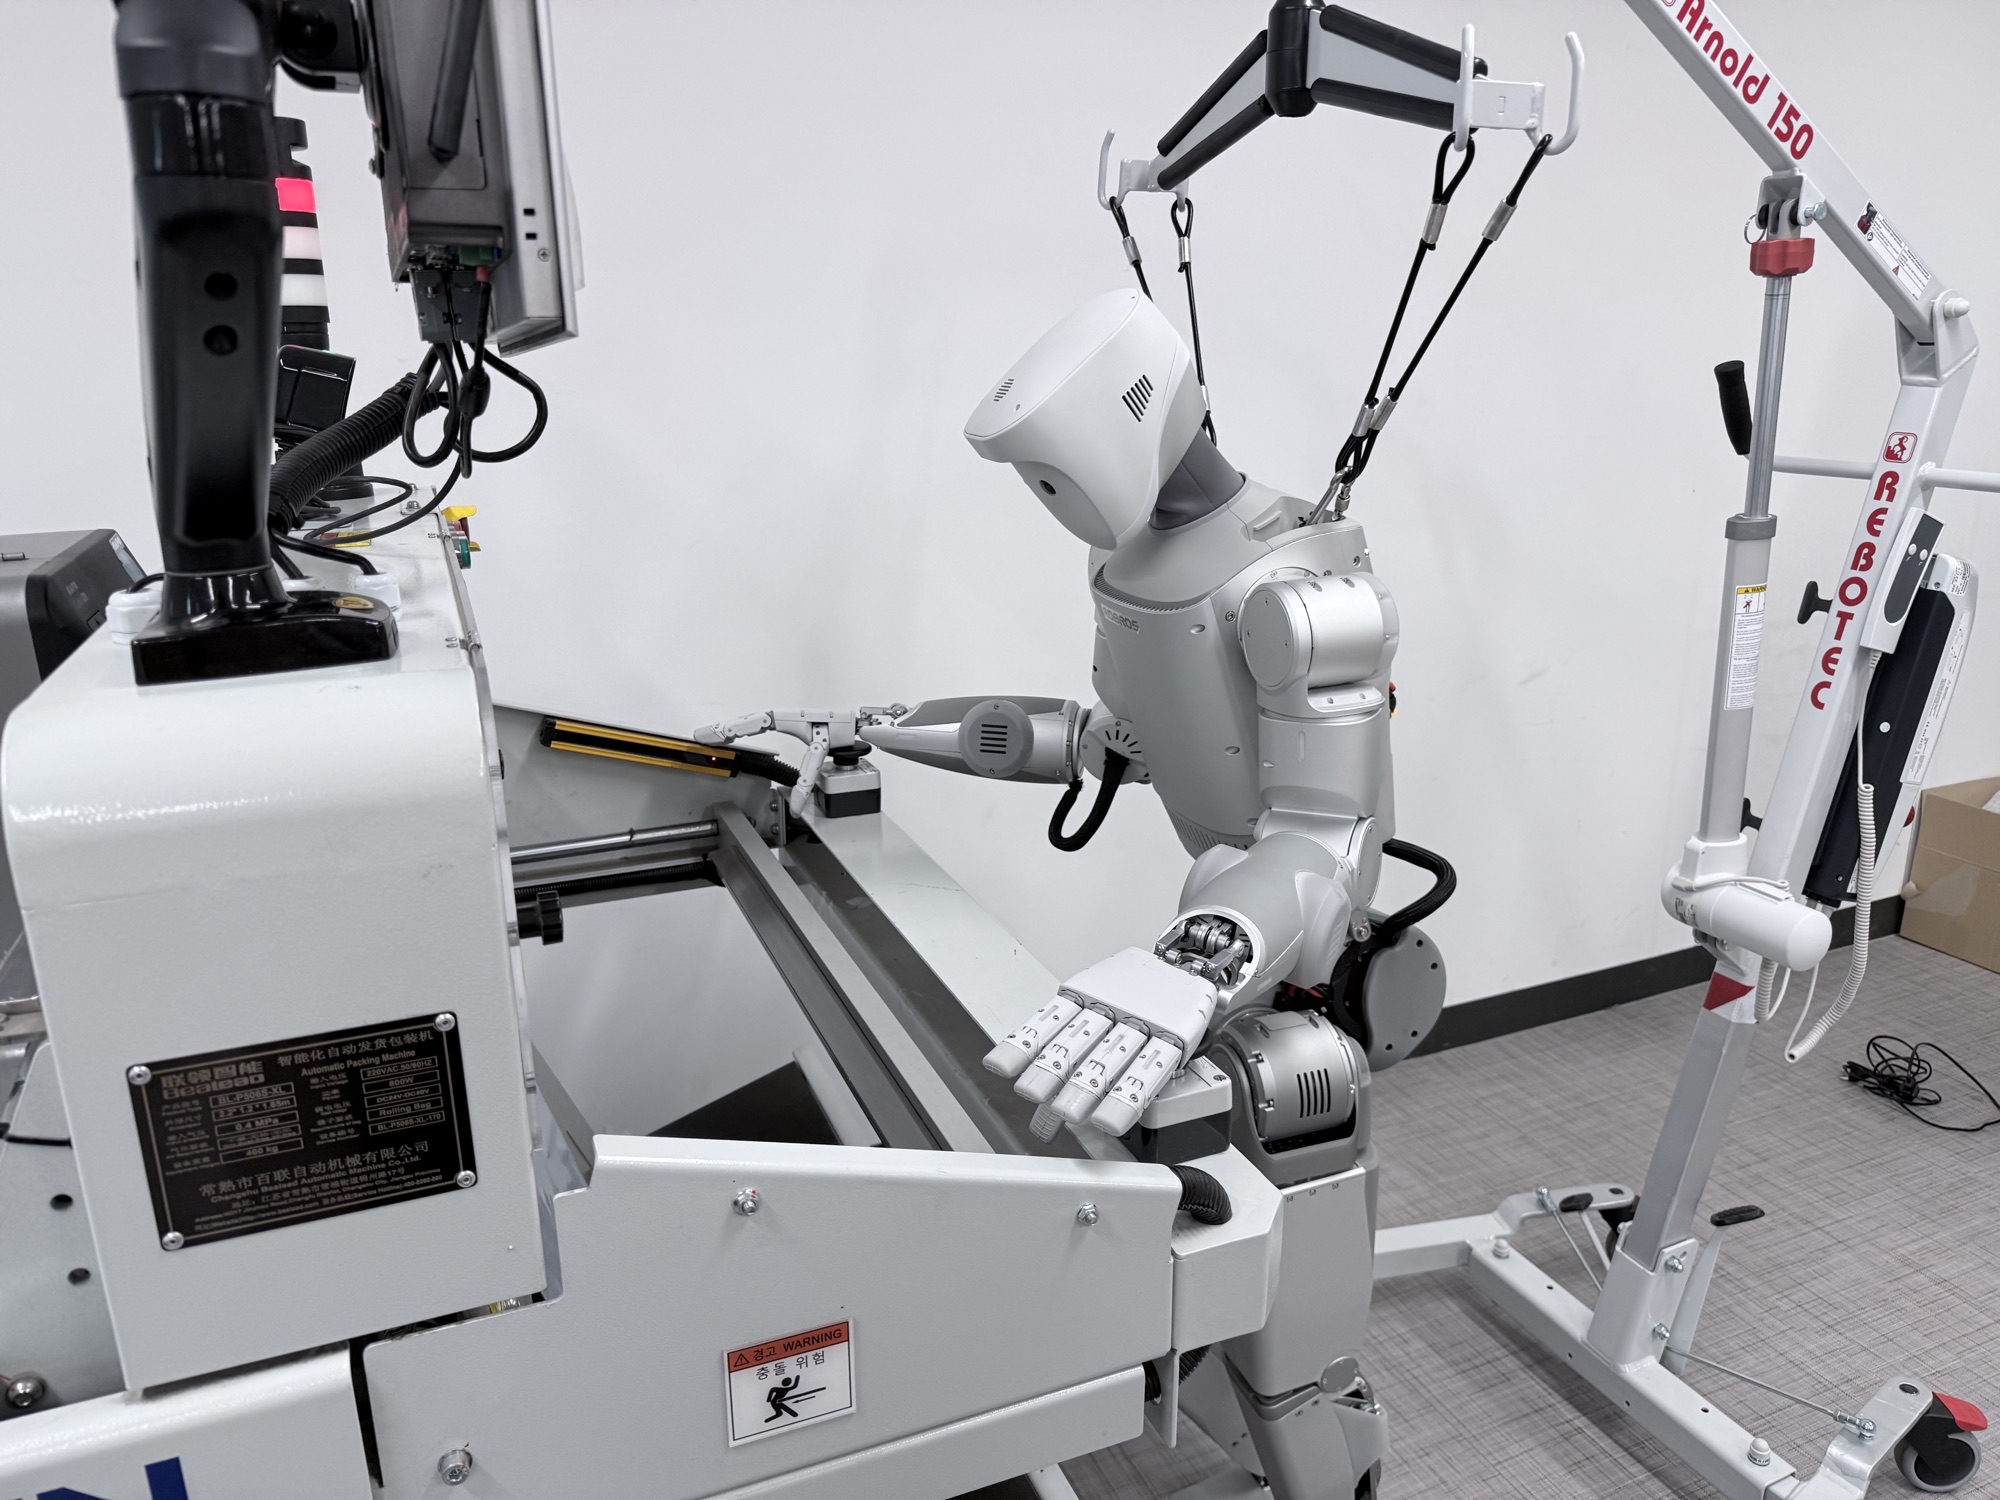
기구학·폐연쇄(closed-chain)·작업 제약 조건 아래에서 실행 가능한 파지와 동작을 계획합니다. 단일 로봇 팔부터 전신 시스템까지 다룹니다.
- Grasp Planning
- Whole-body Motion Planning
- Constrained Motion Planning
- GPU-Parallel Planning
관련 논문
- PATACON: GPU-Parallel Tangent-Bundle RRT-Connect for Constrained Motion Planning Preprint 2026arXiv
- Connectivity-Aware Representations for Constrained Motion Planning via Multi-Scale Contrastive Learning IEEE ICRA 2026arXiv
- A Constrained Motion Planning Method Exploiting Learned Latent Space for High-Dimensional State and Constraint Spaces IEEE/ASME T-MECH 2024Paper
- Motion Planning for Closed-Chain Constraints Based on Probabilistic Roadmap With Improved Connectivity IEEE/ASME T-MECH 2022Paper