Dynamic Robotic Embodiment & Autonomous Manipulation Lab.

We study dynamic robot systems and autonomous manipulation — from robot arms to wheeled mobile manipulators and humanoids.
About

Introduction

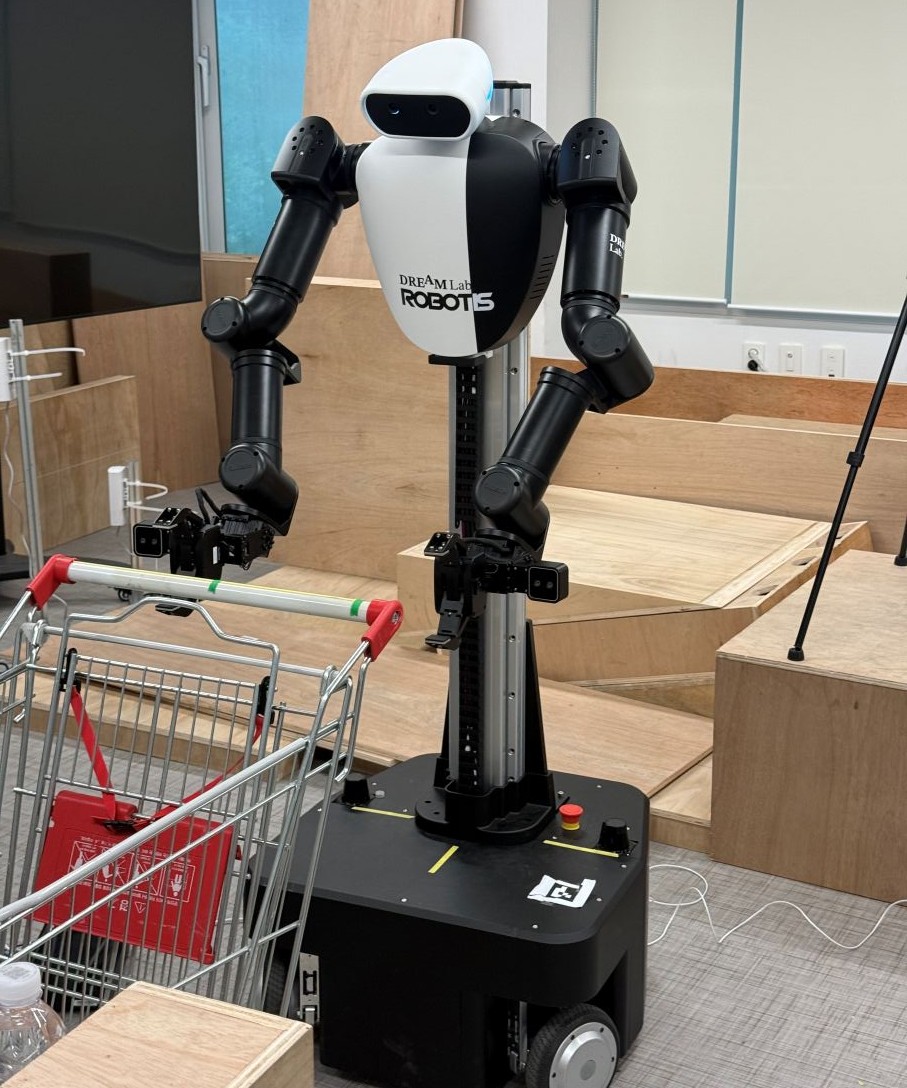
DREAM Lab. studies dynamic robot systems and autonomous manipulation. Centered on tasks performed with robot arms, we build mobile manipulation systems that combine arms with a variety of mobile platforms, such as wheeled robots and humanoids.

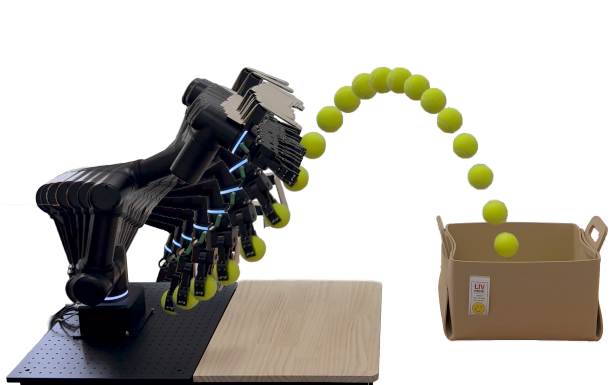
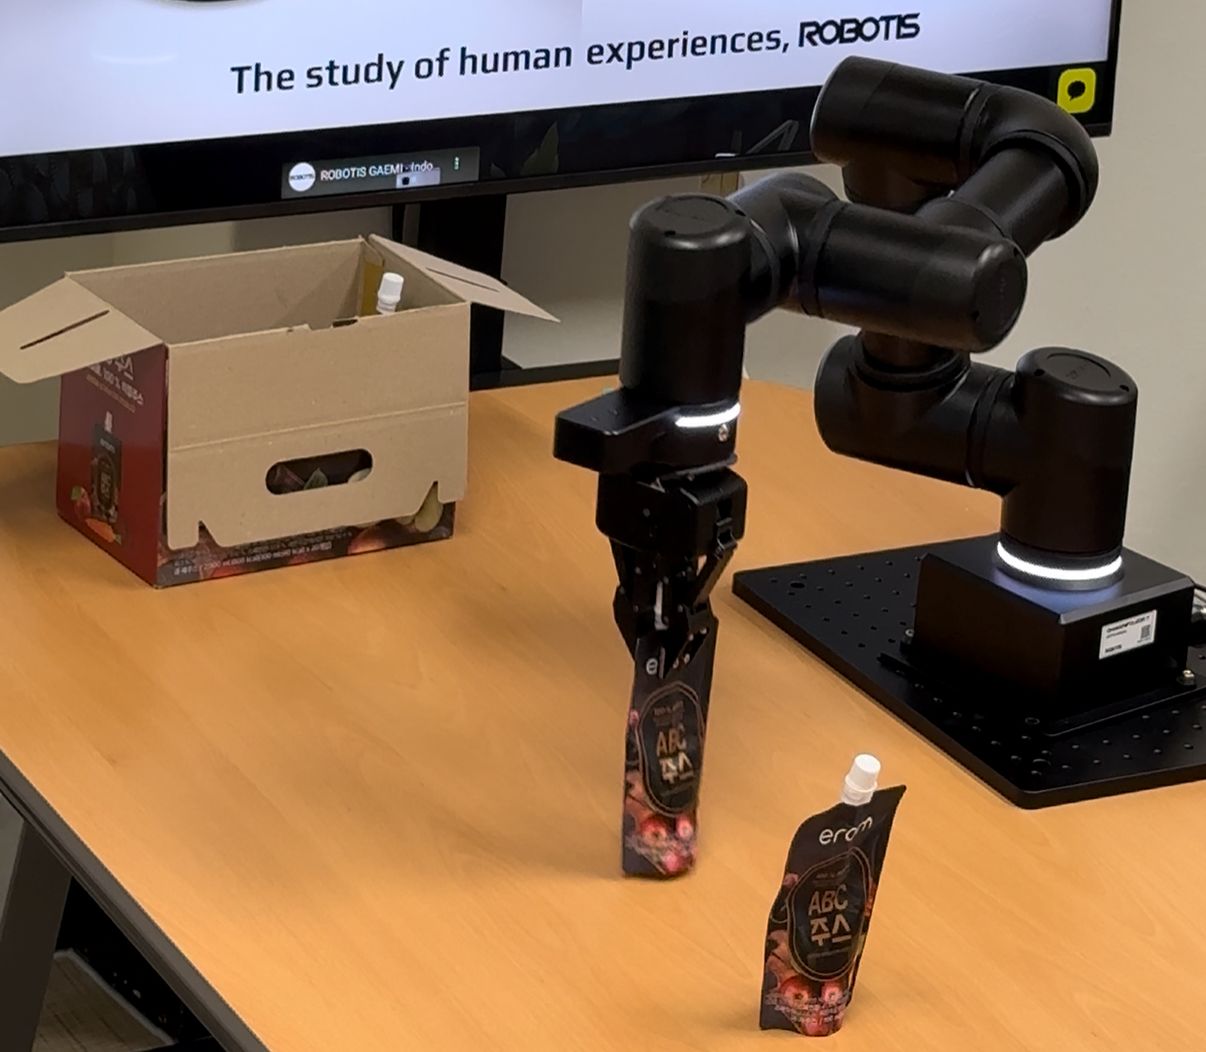
Beyond conventional manipulation of static objects, we use these platforms to handle dynamic situations — wiping a table, assembling deformable parts, and more — through reinforcement learning, imitation learning, and related methods.

To support this research, we also work on efficient data collection and optimal general-purpose hardware.

KeywordsRobots, Artificial Intelligence, Physical AI, Embodied AI, Digital Twin, Manipulation, Autonomous System, Mobile Manipulator, AI Robots
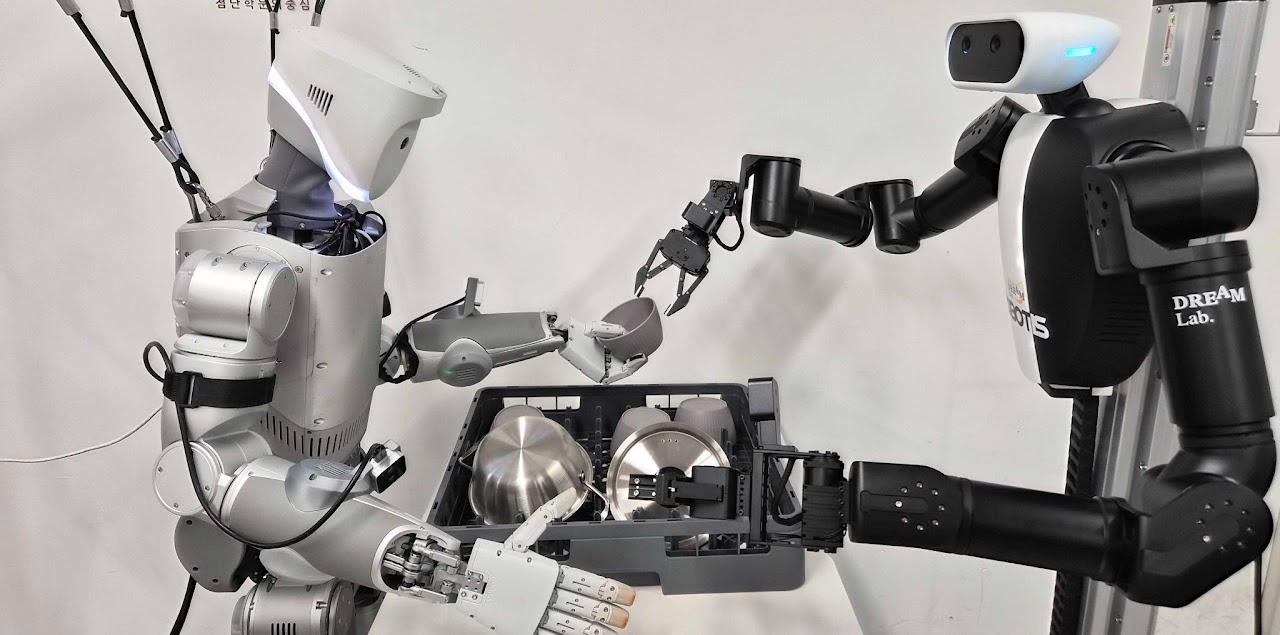
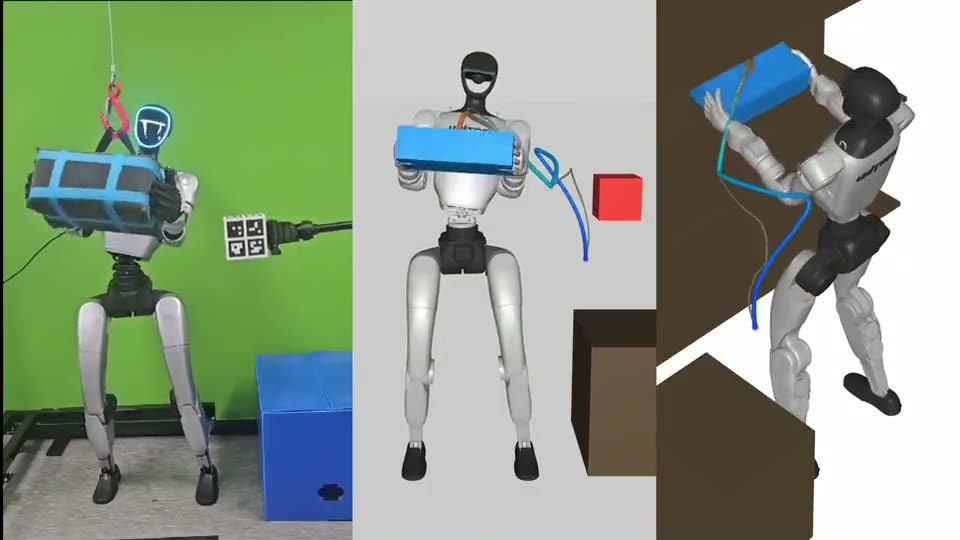
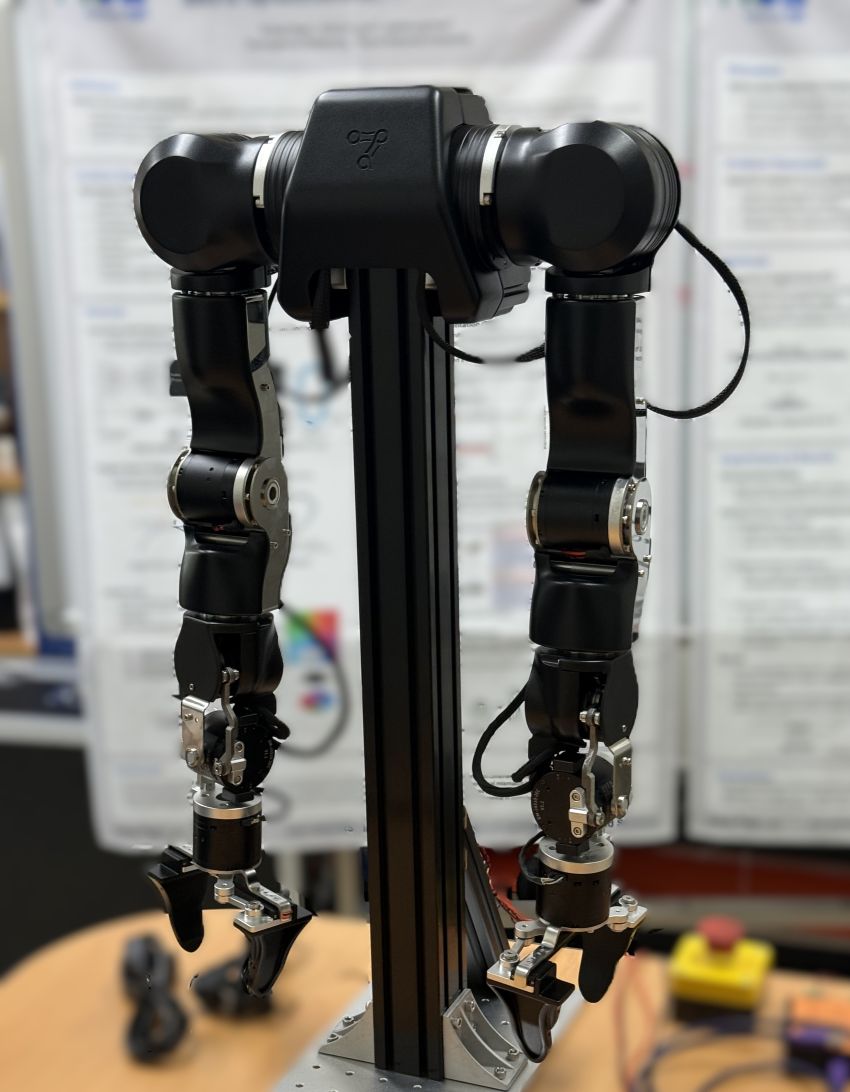
Dual-arm humanoid robots manipulating objects

Research

Research Domains

Research topics
Humanoids
Humanoids

01

Humanoids

  • Mobile Manipulation
  • Whole-body Manipulation

02

Manipulation

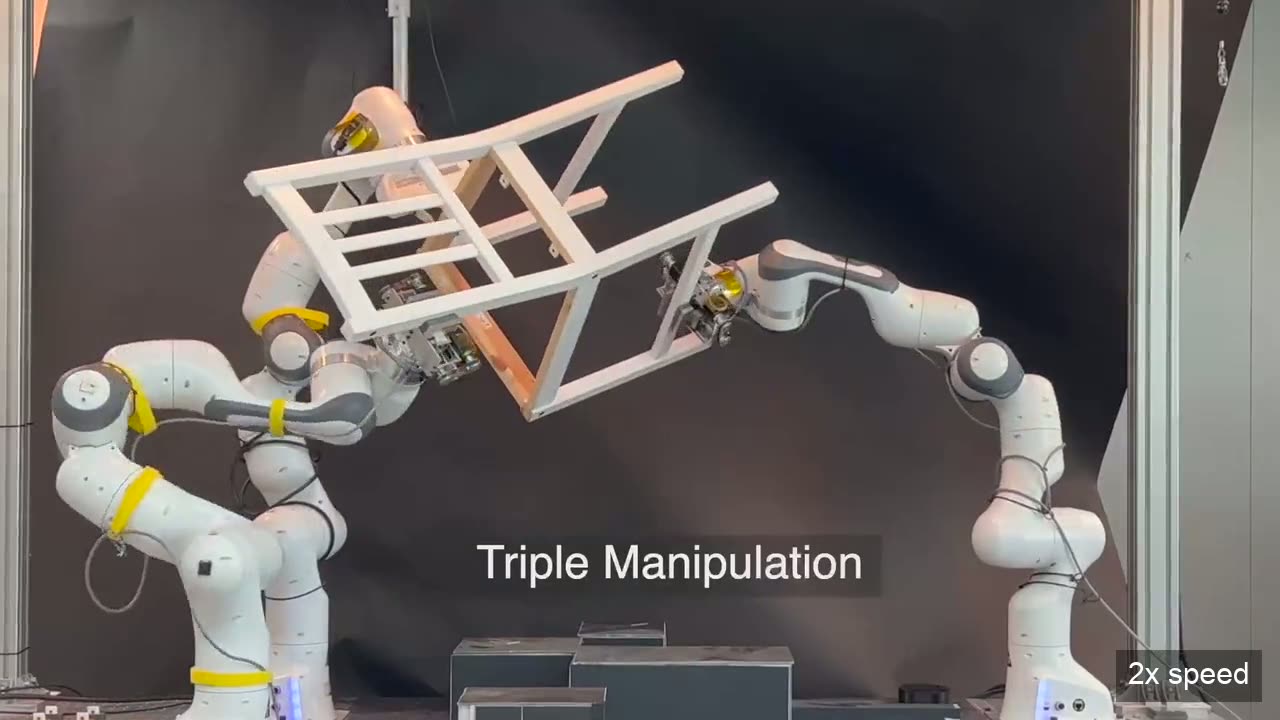
  • Cooperative Manipulation
  • Motion Planning and Control
  • Imitation Learning
  • Reinforcement Learning
  • Physical AI

News

Latest News

All news
  • Paper
    We published the project page for HITMEN, our hybrid interface for humanoid teleoperation — an HMD for the head, chest-mounted VR controllers for the torso, shoulder-mounted leader arms for the arms, and VR together with wrist cameras for the fingers. It anticipates the next second of hand-tracking reliability from recent motion and shifts finger control toward the wrist cameras when tracking degrades. All six of our graduate students are authors. Project page
  • Paper
    We published the project page for PATACON, our work on constrained motion planning. It picks expansion directions inside local tangent spaces and projects and validates several candidate edges in parallel on the GPU, reaching up to 11.25x lower planning latency than a GPU baseline from 7-DoF manipulators to 35-DoF whole-body humanoids, with real-robot replanning against a moving obstacle. arXiv:2610.13195 Project page
  • Event
    Invited talk for our internship program: “Reproducible ROS 2 Systems — From Trial and Error to Research” (Sanghoon Lee, Ph.D., DGIST). Event page
  • Award
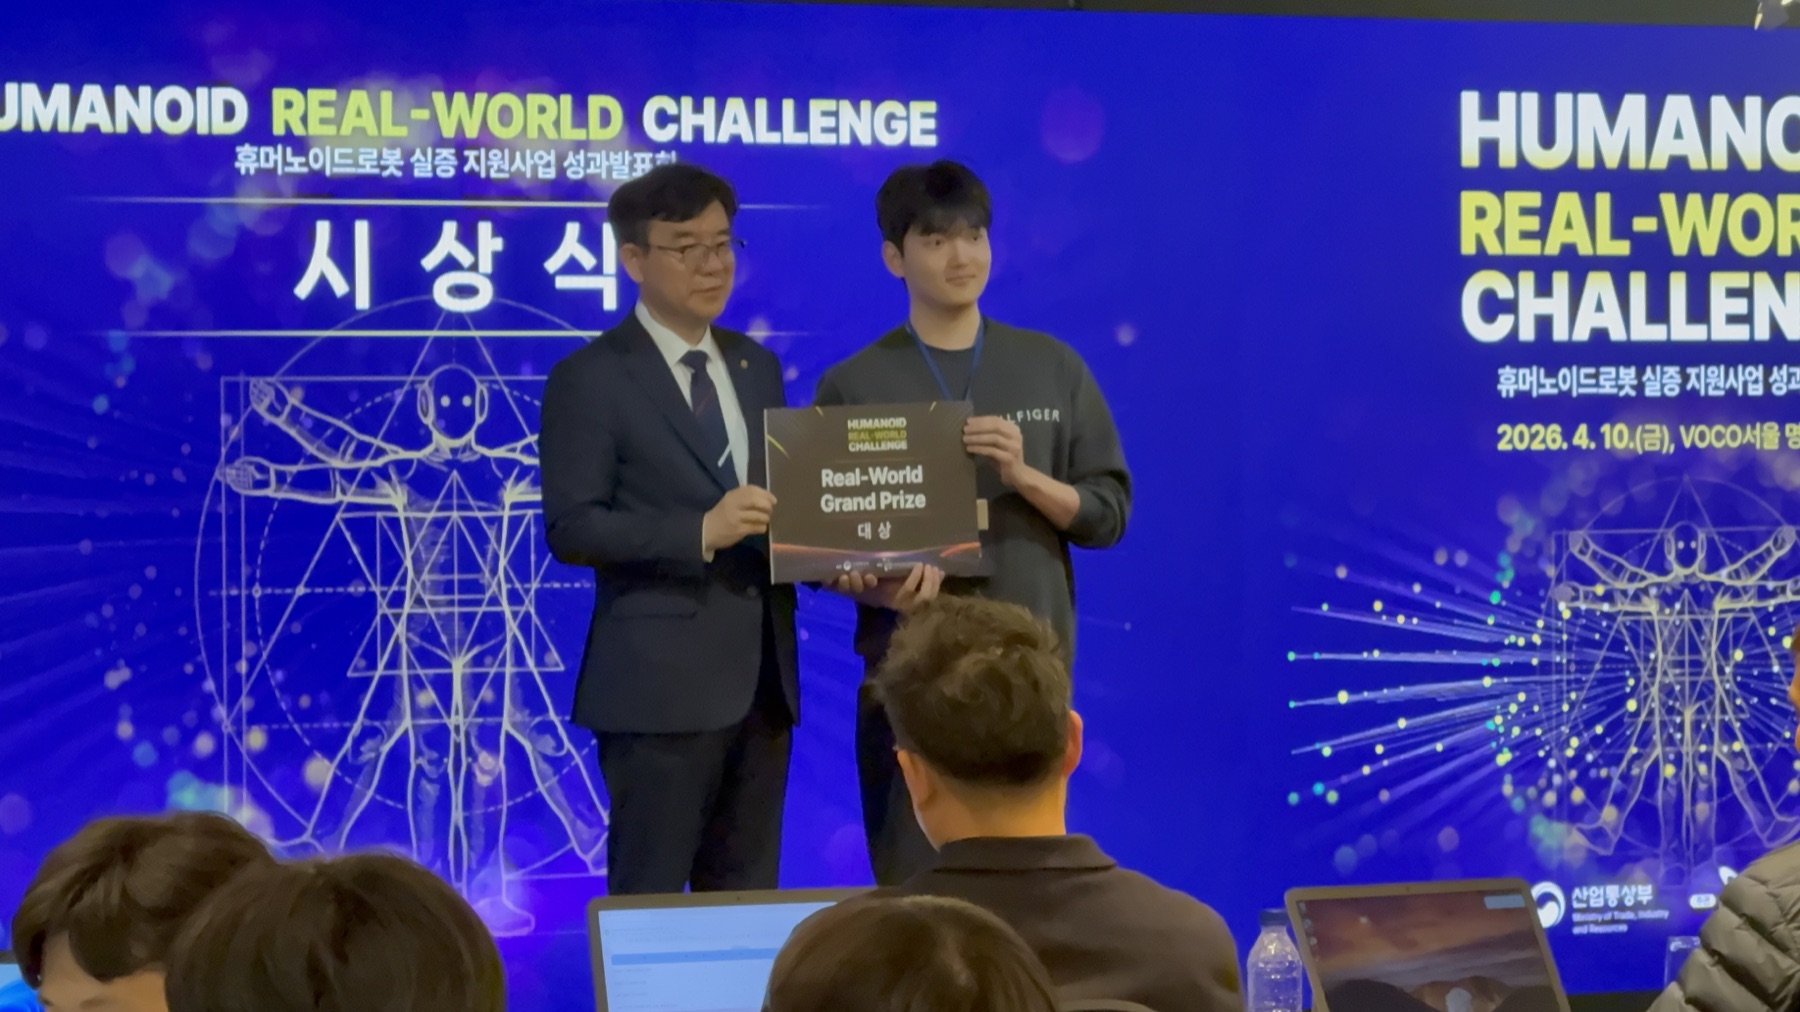
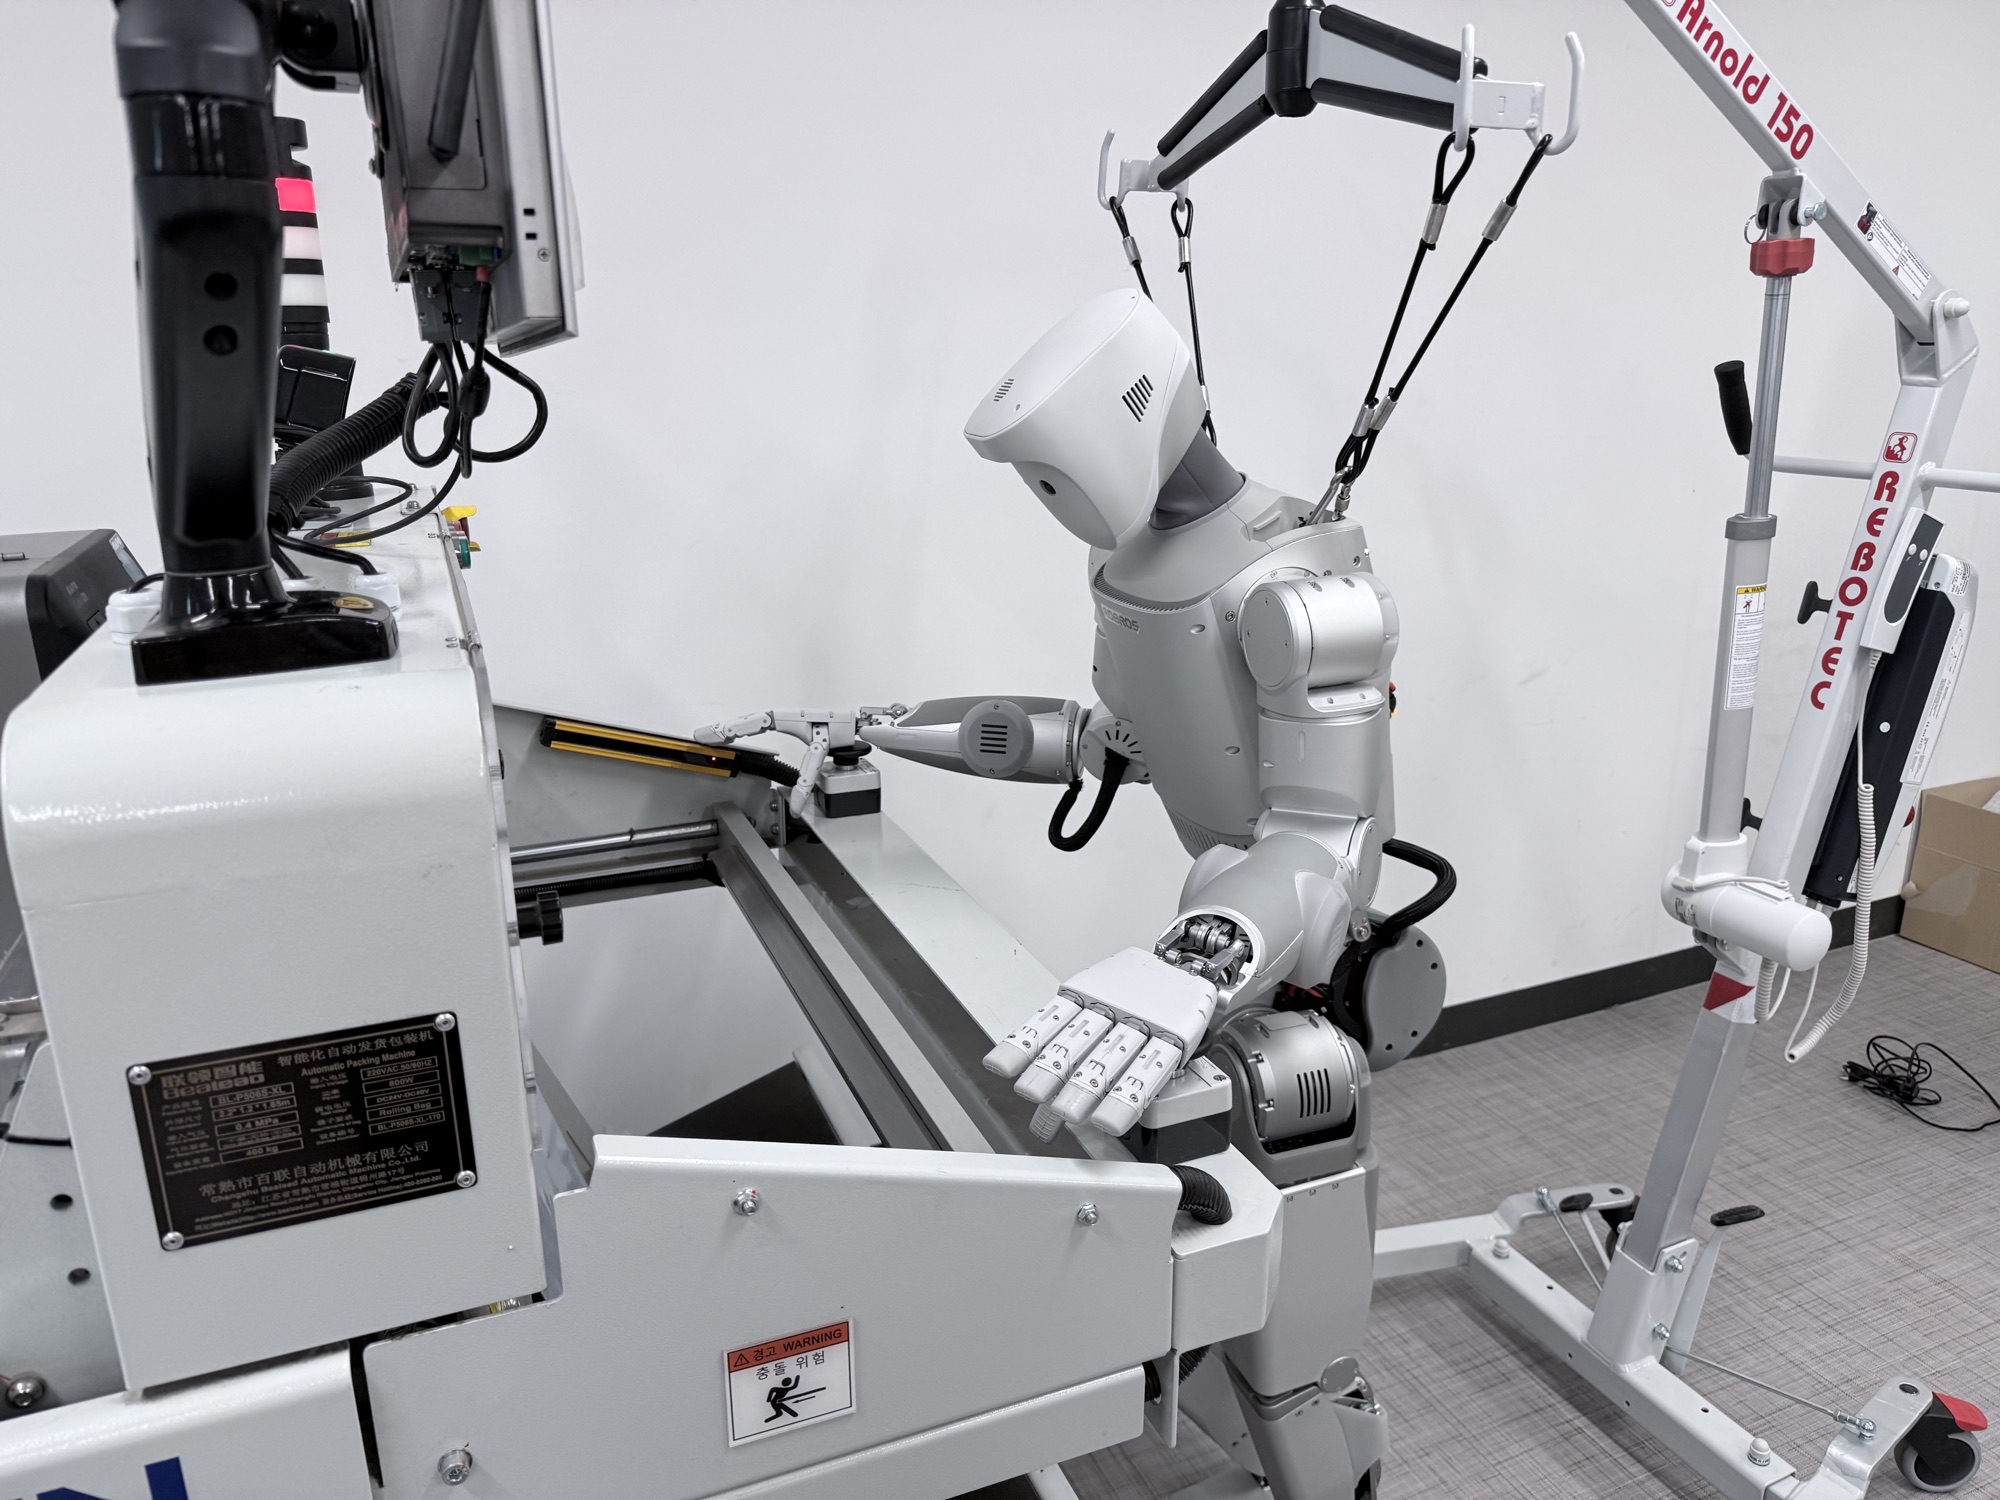
    DREAM Lab. won 1st place at the KIRIA Humanoid Real-World Challenge for automating garment packing with the humanoid IGRIS at a Lotte Global Logistics site. 🏆 The Robot Times
  • Event
    ROSCon Korea 2026, Korea’s first official ROS developer conference, chaired by Prof. Suhan Park, was held at Kwangwoon University’s Pangyo Campus. The Korea Times
  • Grant
    DREAM Lab. won a government grant from the Ministry of Trade, Industry and Resources (MOTIR) — Development of a humanoid robot specialized for distribution processes based on AI foundation models (joint research). Press

Publications

Selected Publications

All publications

IEEE/ASME T-MECH 2024

A Constrained Motion Planning Method Exploiting Learned Latent Space for High-Dimensional State and Constraint Spaces

Suhan Park, Suhyun Jeon, Jaeheung Park

Media

In Action

YouTube channel

DREAM Lab.

Humanoid Robot for Parcel Packaging — Physical AI

A humanoid robot performing a parcel-packaging process — Physical AI research at DREAM Lab.

“Packing in a snap”: the logistics center's sleepless robot intern

KBS News 9 · 2026.04.10
Robots in training before deployment, starting with night shifts

TV Chosun News 7

User Interview EP.1 | Kwangwoon University

ROBROS

“Packing in a snap”: the logistics center's sleepless robot intern

KBS · 2026.04.10

“Packing in a snap”: the logistics center's sleepless robot intern

KBS · 2026.04.11

Robots for parcel packing and sorting — logistics industry adopts AI robots

KNN News

What happens when fromis_9's Chaeyoung visits an engineering lab [EP.20]

MUSINSA TV