Research output

Publications

Papers by DREAM Lab. members. Names in bold are lab members.

2026
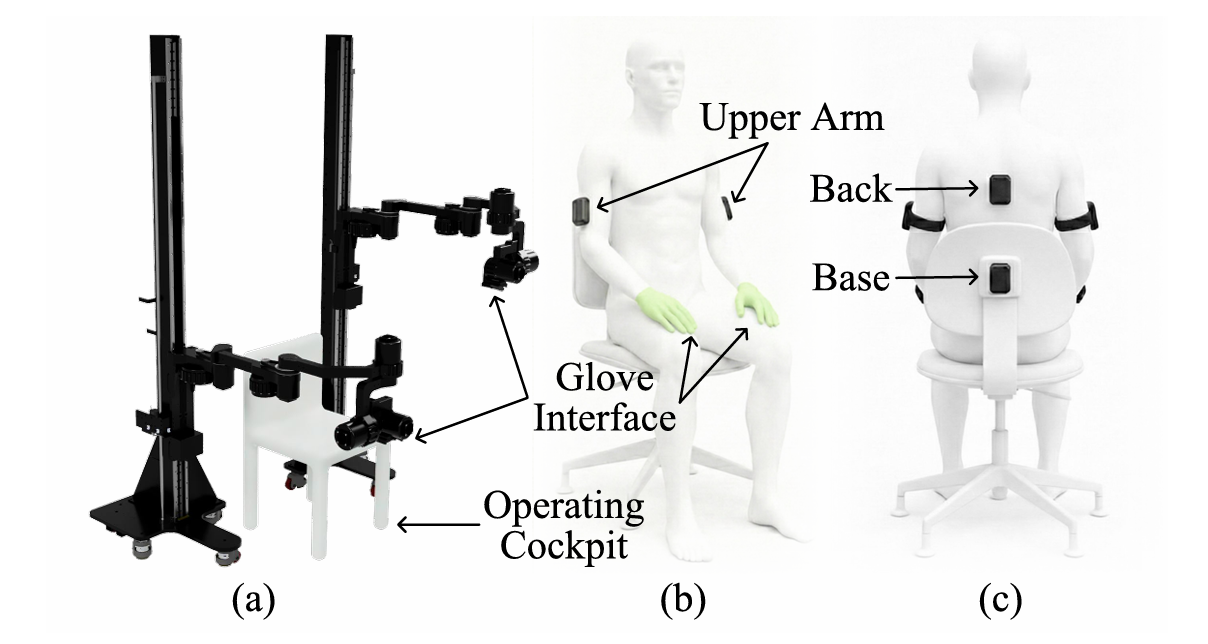
SNU-Avatar Haptic Arm: A Hybrid QDD/DD Operator Interface for Teleoperation
SNU-Avatar Haptic Arm: A Hybrid QDD/DD Operator Interface for Teleoperation

Eunho Sung, Seungbin You, Jaeyong Shin, Suhan Park, Sungmoon Hur, Jaehun Kim, Seunghwan Byun, Chaiyong Mun, Haeseong Lee, Dongjun Kim, Jaeheung Park

IEEE Access 2026 Journal

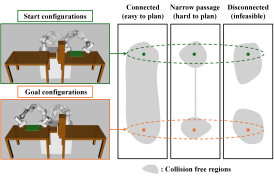
Connectivity-Aware Representations for Constrained Motion Planning via Multi-Scale Contrastive Learning

Connectivity-Aware Representations for Constrained Motion Planning via Multi-Scale Contrastive Learning

Suhyun Jeon, Yumin Lim, Woo-Jeong Baek, Hyeonseo Kim, Suhan Park, Jaeheung Park

IEEE ICRA 2026 Conference

Mechanical Design of a Giant Human Riding Biped Humanoid Robot, Method II

Ill-Woo Park, Junghyun Oh, Suhan Park

IJHR 2026 Journal

2025

GUARD: Toward a Compromise between Traditional Control and Learning for Safe Robot Systems

Johannes A. Gaus, Junheon Yoon, Woo-Jeong Baek, Seungwon Choi, Suhan Park, Jaeheung Park

IROS Workshop 2025 Workshop

2024

A Constrained Motion Planning Method Exploiting Learned Latent Space for High-Dimensional State and Constraint Spaces

Suhan Park, Suhyun Jeon, Jaeheung Park

IEEE/ASME T-MECH 2024 Journal

Performance Evaluation of Robotic Physics Engine for Mobile Manipulator Simulation
Kwanwoo Lee, Junheon Yoon, Suhan Park, Jaeheung Park

JKROS 2024 Journal

Intuitive and Interactive Robotic Avatar System for Tele-Existence: TEAM SNU in the ANA Avatar XPRIZE Finals

Intuitive and Interactive Robotic Avatar System for Tele-Existence: TEAM SNU in the ANA Avatar XPRIZE Finals

TEAM SNU Members

IJSR 2024 Journal

2023

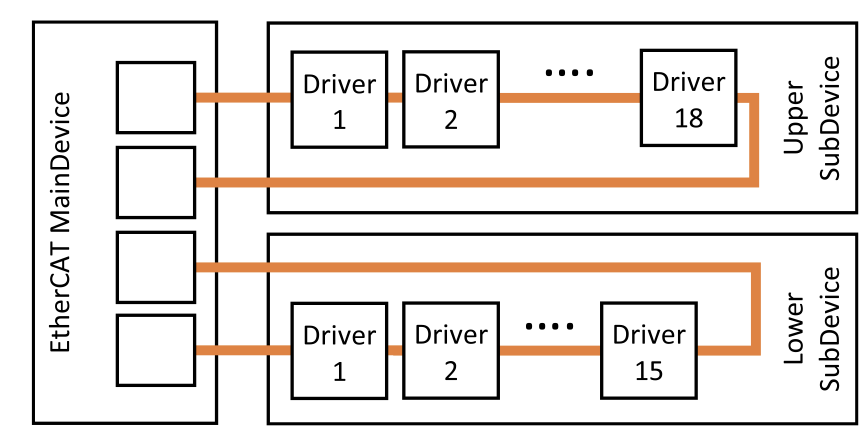
Dual-Channel EtherCAT Control System for 33-DOF Humanoid Robot TOCABI

Dual-Channel EtherCAT Control System for 33-DOF Humanoid Robot TOCABI

Junewhee Ahn, Suhan Park, Jaehoon Sim, Jaeheung Park

IEEE Access 2023 Journal

Virtual Reality Based Intuitive Spatial Visual Interface for Avatar Robot System

Jaeyong Shin, Junewhee Ahn, Suhan Park, Beomyeong Park, Junhyeok Cha, Jaeheung Park

ICCAS 2023 Conference

Operator-Avatar Texture Feedback Approach using Hand-eye Camera and Force Sensor

Suhan Park, Junhyeok Cha, Jaeheung Park

ICRA Workshop 2023 Workshop

2022

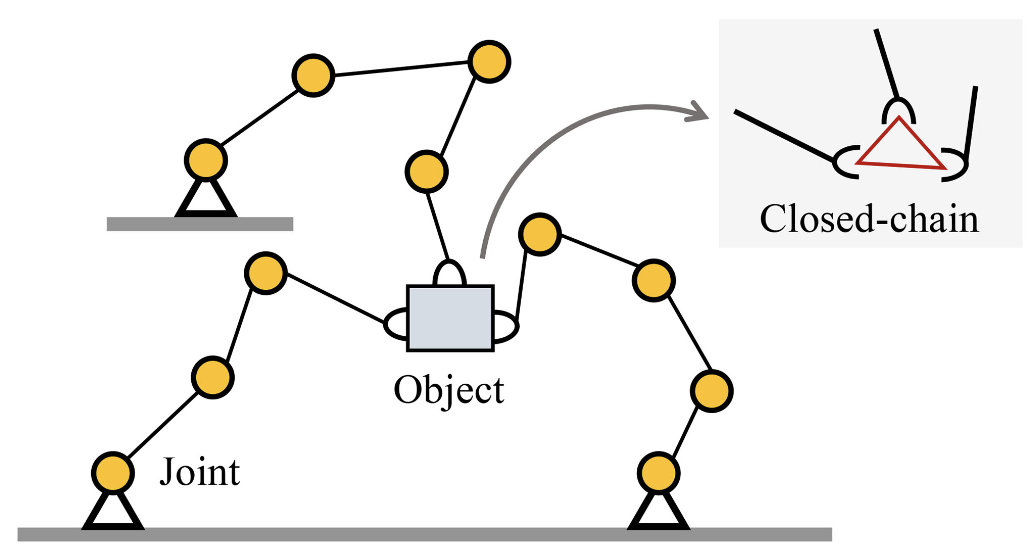
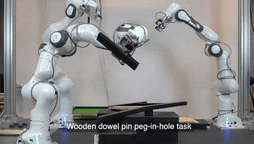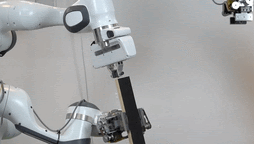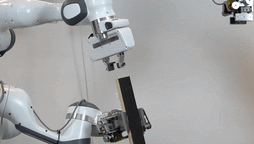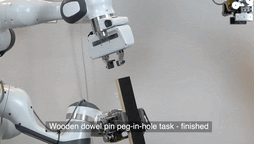
Motion Planning for Closed-Chain Constraints Based on Probabilistic Roadmap With Improved Connectivity
Motion Planning for Closed-Chain Constraints Based on Probabilistic Roadmap With Improved Connectivity

Keunwoo Jang, Jiyeong Baek, Suhan Park, Jaeheung Park

IEEE/ASME T-MECH 2022 Journal

Scalable Learned Geometric Feasibility for Cooperative Grasp and Motion Planning

Suhan Park, Hyoung Cheol Kim, Jiyeong Baek, Jaeheung Park

IEEE RA-L 2022 Journal

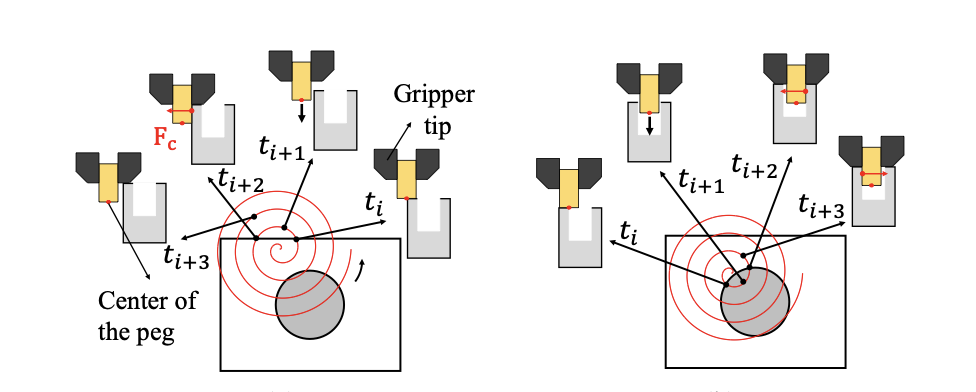
Contact State Estimation for Peg-in-Hole Assembly Using Gaussian Mixture Model
Contact State Estimation for Peg-in-Hole Assembly Using Gaussian Mixture Model

Haeseong Lee, Suhan Park, Keunwoo Jang, Seungyeon Kim, Jaeheung Park

IEEE RA-L 2022 Journal

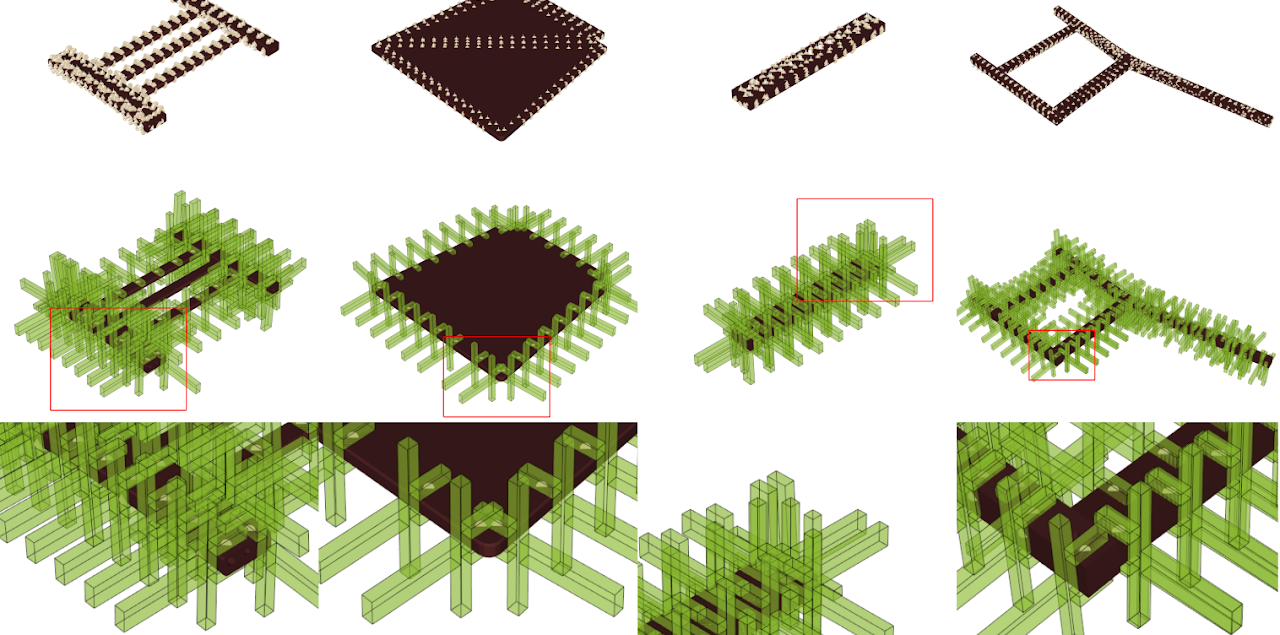
Robotic furniture assembly: task abstraction, motion planning, and control

Robotic furniture assembly: task abstraction, motion planning, and control

Suhan Park, Haeseong Lee, Seungyeon Kim, Jiyeong Baek, Keunwoo Jang, Hyoung Cheol Kim, Myeongsoo Kim, Jaeheung Park

ISR 2022 Journal

Weighted Hierarchical Quadratic Programming: Assigning Individual Joint Weights for Each Task Priority
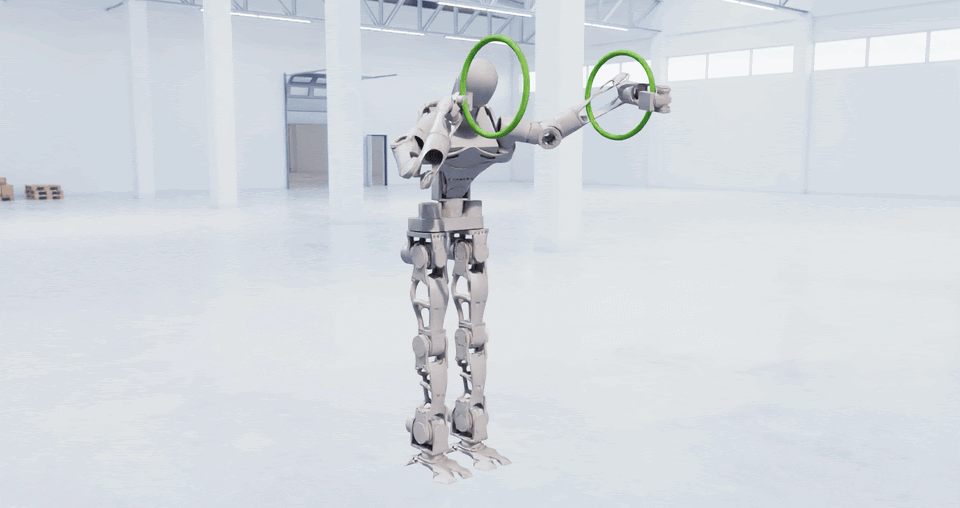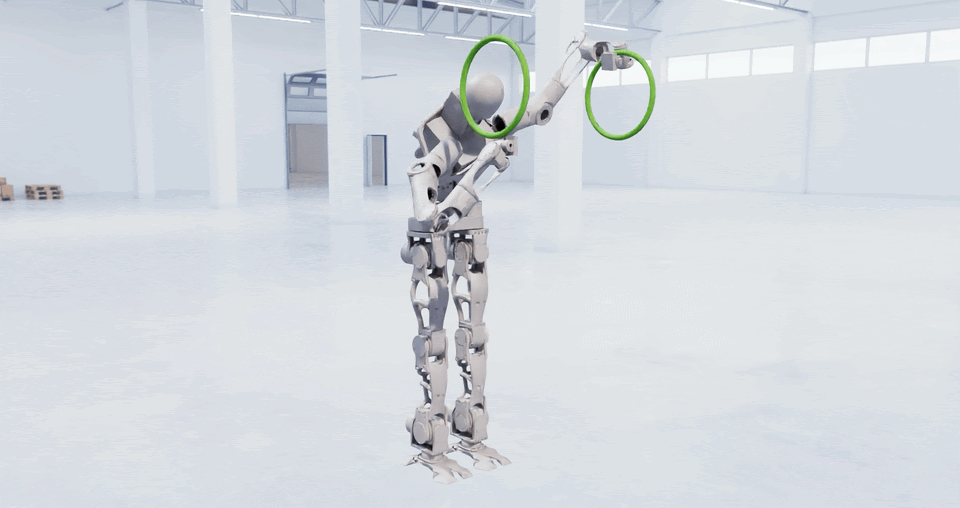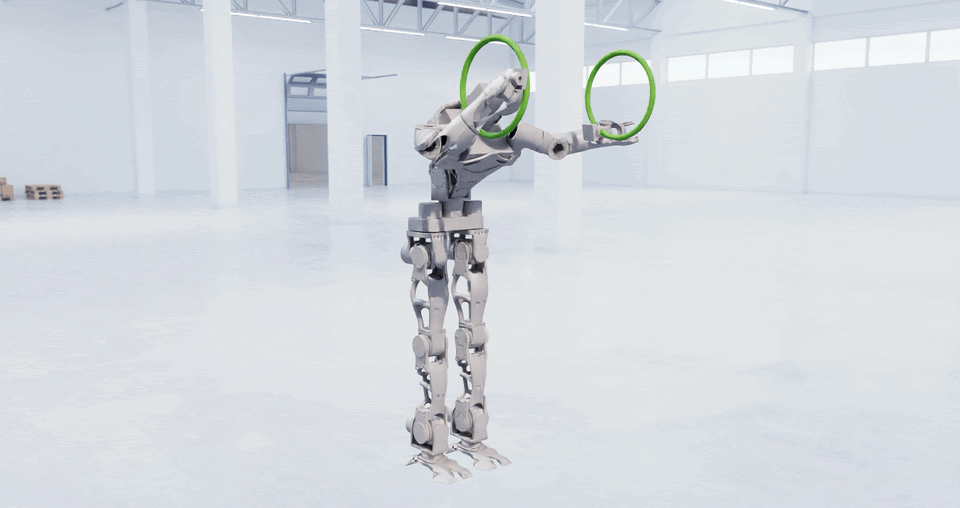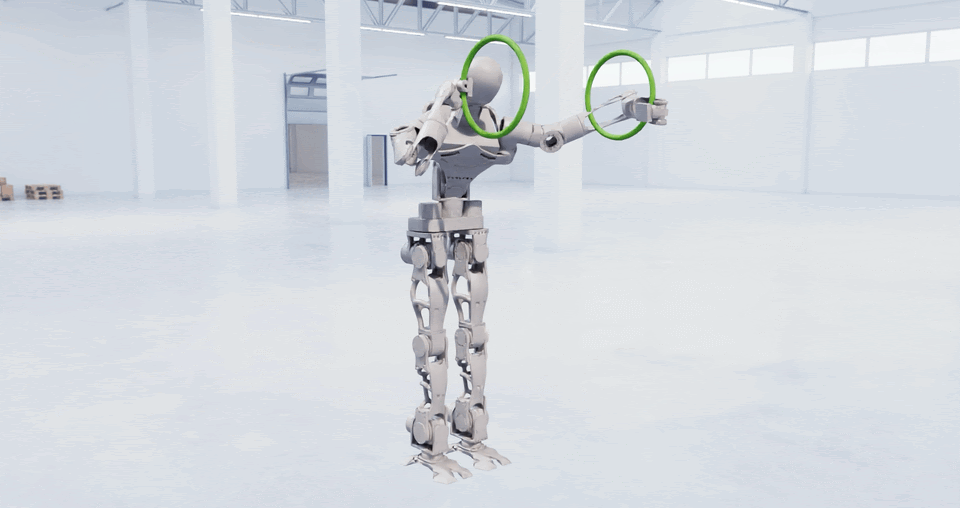
Keunwoo Jang, Sanghyun Kim, Suhan Park, Junhyung Kim, Jaeheung Park

ISR 2022 Journal

NODE IK: Solving Inverse Kinematics with Neural Ordinary Differential Equations for Path Planning

NODE IK: Solving Inverse Kinematics with Neural Ordinary Differential Equations for Path Planning

Suhan Park, Mathew Schwartz, Jaeheung Park

ICCAS 2022 Conference

2020

Rigid Grasp Candidate Generation for Assembly Tasks

Rigid Grasp Candidate Generation for Assembly Tasks

Suhan Park, Jiyeong Baek, Seungyeon Kim, Jaeheung Park

IEEE/ASME AIM 2020 Conference

2019

Continuous Task Transition Approach for Robot Controller Based on Hierarchical Quadratic Programming

Continuous Task Transition Approach for Robot Controller Based on Hierarchical Quadratic Programming

Sanghyun Kim, Keunwoo Jang, Suhan Park, Yisoo Lee, Sang Yup Lee, Jaeheung Park

IEEE RA-L 2019 Journal