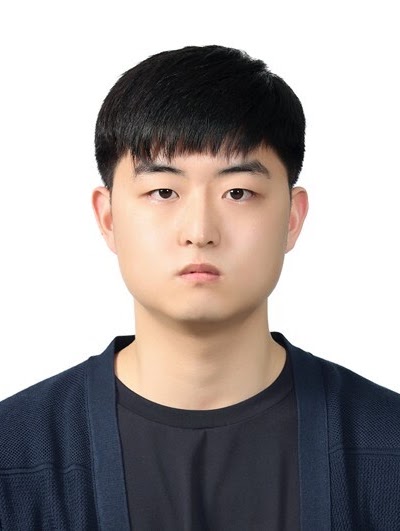
Junho An

Graduate Student

Junho An안준호

Research Interests

  • Imitation Learning
  • Constrained Motion Planning

Current Research

Constrained motion planning

Planning paths that keep equality constraints such as a fixed end-effector pose or a fixed relative transform between two arms. I am a co-author of PATACON, which runs the tangent-bundle search in parallel on the GPU.

  • Motion Planning
  • Constrained Manifold

Publications

  • PATACON: GPU-Parallel Tangent-Bundle RRT-Connect for Constrained Motion Planning Preprint 2026Project

All publications

All members