
Principal Investigator
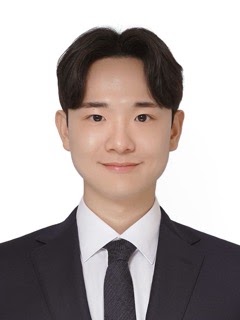
Suhan Park박수한
Assistant Professor, Department of Robotics, Kwangwoon University
DREAM Lab. (Dynamic Robotic Embodiment & Autonomous Manipulation Lab.) Principal Investigator (PI)
Email park94@kw.ac.kr
Suhan Park is the Principal Investigator (PI) of DREAM Lab. (Dynamic Robotic Embodiment & Autonomous Manipulation Lab.) and Assistant Professor in the Department of Robotics at Kwangwoon University. The lab is located at #639 Hwado-gwan, 20 Gwangun-ro, Nowon-gu, Seoul, Korea, and the email address is park94@kw.ac.kr.
- Name
- Suhan Park (박수한)
- Position
- Assistant Professor
- Role
- Principal Investigator (PI), DREAM Lab. (Dynamic Robotic Embodiment & Autonomous Manipulation Lab.)
- Affiliation
- Department of Robotics, Kwangwoon University
- park94@kw.ac.kr
- Office
- #639 Hwado-gwan, 20 Gwangun-ro, Nowon-gu, Seoul, Korea
- Lab website
- https://drl.kw.ac.kr/
Research Interests
- Robot Task and Motion Planning
- Robot Intelligence
- Embodied AI
Education
- 2017 – 2024Ph.D., Dept. of Transdisciplinary Studies, Seoul National University (Advisor: Prof. Jaeheung Park)
- 2013 – 2017B.S., Robotics, Kwangwoon University (Achievement Award)
Experience
- 2025 –Assistant Professor, Department of Robotics, Kwangwoon University
- 2024 – 2025Staff Engineer, Samsung Electronics
Activities
- Associate Editor, IEEE International Conference on Robotics and Automation (ICRA)
- Associate Editor, Journal of Mechanical Science and Technology
- Robotics Bootcamp (Linux, ROS, and dynamic simulator lectures)
- Alumnus of RO:BIT, Kwangwoon University robot game team
Selected Publications
- PATACON: GPU-Parallel Tangent-Bundle RRT-Connect for Constrained Motion Planning Preprint 2026Project
- LiPo: A Lightweight Post-optimization Framework for Smoothing Action Chunks Generated by Learned Policies IJCAS 2025Paper
- A Constrained Motion Planning Method Exploiting Learned Latent Space for High-Dimensional State and Constraint Spaces IEEE/ASME T-MECH 2024Paper
- Scalable Learned Geometric Feasibility for Cooperative Grasp and Motion Planning IEEE RA-L 2022Paper